Our take
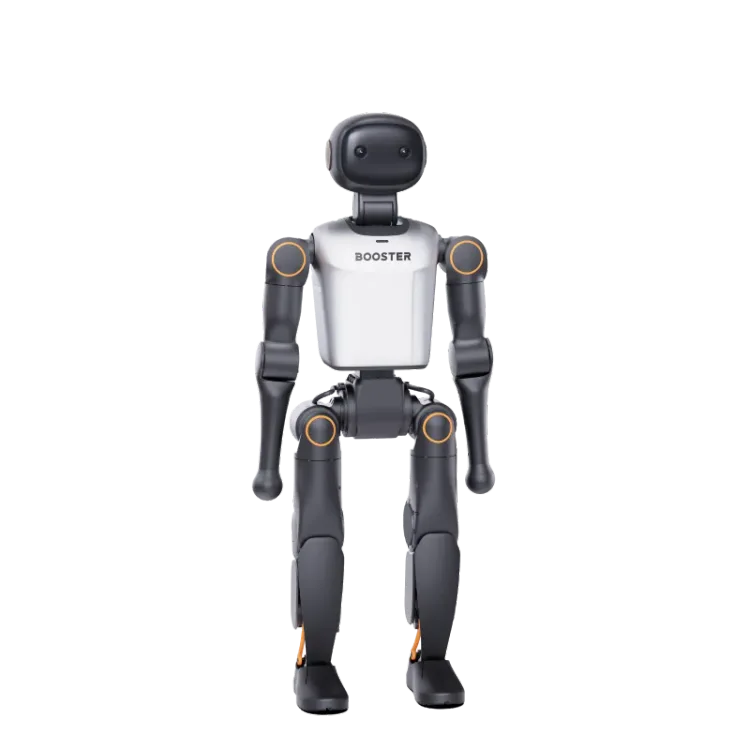
Booster Robotics K1
A serious small humanoid for university teams and embodied-AI developers, not a consumer robot. Its strongest evidence is the developer ecosystem and real hands-on use; buyers should expect to write the behaviours they want rather than receive a useful autonomous assistant.
Developer reports praise the compact size, resilience, accessible SDK and enough compute and sensing for research, RoboCup and reinforcement-learning work.
Runtime is short, useful autonomy is largely the developer's responsibility, and the price only makes sense for education or research rather than household chores.
Universities, RoboCup teams and embodied-AI developers.
General consumers or continuous all-day operation.
- 48–200 TOPS compute
- Stereo depth camera
- Secondary development supported
What the evidence shows
K1’s compact body and development support make it relevant to robotics education and experimentation. The official versions differ enough that the cheapest unit and a research configuration should be compared carefully.
The package changes the working session
Booster lists Geek, Education and Professional versions with different computing hardware, batteries and warranty periods. The advertised walking duration is substantially shorter for the smallest battery. Those differences affect a teaching session more directly than a performance video.
[1]A platform to build on
The official page links the robot to competition and education uses and includes secondary development. That is a clear use case for a team writing behaviours. It does not establish that K1 arrives with dependable home assistance, or provide independent evidence of maintenance needs across years of use.
[1]Available evidence describes the platform; it does not establish everyday household ownership or long-term reliability.
Sources (1)
- Booster Robotics K1 official documentation ↗Manufacturer information
Full specifications
- Height
- ~95cm
- Weight
- ~19.5kg
- Degrees of freedom
- Total DoFs: 22 (per leg 6, per arm 4, head 2)
- Peak joint torque
- 60N·m
- Compute
- 48–200 TOPS
- Runtime
- 30 or 80 minutes
- Connectivity
- Wi-Fi and Bluetooth 5.2
- Battery
- 2Ah (Geek); 5Ah (Education/Professional)
- Run time
- 30min (walking 0.4m/s) Geek; 80min (walking 0.4m/s) Education/Professional
- Sensors
- Stereo Depth Camera, 9-axis IMU, Circular 3-Mic Array + speaker
Sources
Videos
- Charbax: Booster Robotics humanoid dev kit: T1/K1 RL balance, Jetson Orin, ROS2 ↗
- Peter Kappes: Booster Robotics humanoid robot K1 at CES 2026 ↗
- Search YouTube for Booster Robotics K1 ↗Search results may include similar models; check the model name.